
AI-driven logistics, for food robotics, mostly means one thing: the intelligence moves out of a central server and into the vehicles themselves. AGILOX, the Austrian maker of omnidirectional autonomous mobile robots, is the clearest working example of that shift — its trucks negotiate jobs with each other over a shared network instead of waiting for a master controller to assign them — and the practical consequence for food and beverage plants is that pallet movement can now be automated without re-engineering the building or the production schedule around a fixed route.
That matters more in food than in most industries, because food logistics is the part of a food plant that changes constantly. Product mix shifts weekly, cold stores are rearranged around whatever is in season, and a line that runs yogurt in the morning may run a different SKU by evening. A decentralized fleet adapts to that churn in software; a conveyor or a taped guidepath does not.
Table of Contents
- What AGILOX's swarm approach actually changes
- Why food plants are the hardest case for mobile robots
- What "AI" covers here, and what it doesn't
- What this means for different operations
- How to evaluate a food-plant deployment
- The integration layer is where projects actually fail
- Frequently Asked Questions
What AGILOX's swarm approach actually changes
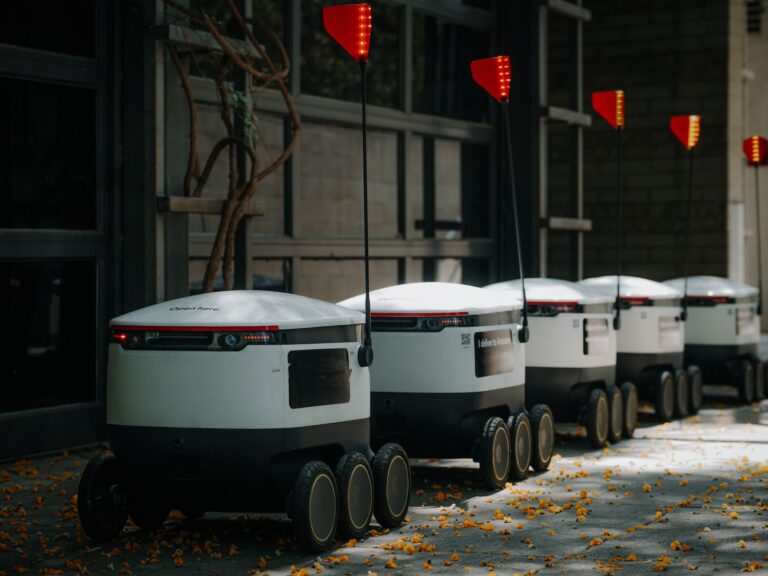
AGILOX builds driverless industrial trucks for intralogistics — the internal movement of pallets, racks and bins inside a plant or warehouse. Two design decisions set them apart. The vehicles are omnidirectional, meaning they can travel sideways and rotate in place rather than needing a turning arc, and they run a distributed control scheme the company calls swarm intelligence, in which each unit holds the map and bids on transport orders. The absence of a central fleet manager is the substantive part.
On a conventional automated guided vehicle (AGV) system, a server computes routes and hands them down; the server is both the brain and the single point of failure. In a swarm model, adding a vehicle is closer to adding a worker than to reconfiguring a system — the new unit joins the network, learns the existing map, and starts taking jobs. The second practical change is navigation. These robots localize against the natural features of the building — walls, racking, structural columns — rather than following magnetic tape, painted lines or reflector targets. For a food producer, that removes the floor work, and floor work in a wet processing area is neither cheap nor welcome.
Why food plants are the hardest case for mobile robots
Food and beverage facilities break several assumptions that mobile robots are built around. Floors are wet and sloped to drains. Areas are washed down with hot water, caustic foam and high-pressure hoses. Temperature zones run from ambient packaging halls to chilled docks to freezers well below zero, and a vehicle crossing between them collects condensation on exactly the optical sensors it navigates with. Hygiene design is the deeper constraint.
Equipment in a food zone needs surfaces that can be cleaned and inspected, no horizontal ledges collecting debris, and no cavities that harbor moisture. Most general-purpose logistics robots, including swarm AMRs, are not built to those standards. The honest reading is that AI-driven logistics in food currently lives in the dry side of the plant: warehouses, packaging halls, palletizing areas, dock staging and inter-building transfer. Cold storage is a separate engineering problem again. Lithium battery performance falls in freezer temperatures, charging behavior changes, and a robot that lives at minus twenty cannot simply be the ambient model with a heater bolted on. Several vendors offer cold-store variants; treat that as a distinct product qualification rather than an option box.
What "AI" covers here, and what it doesn't
The phrase gets stretched. In mobile intralogistics it reliably refers to three things: simultaneous localization and mapping, so the vehicle builds and maintains its own map; perception models that classify what a sensor is seeing, so a pallet stringer is distinguished from a person's leg; and fleet-level decision logic that allocates jobs and resolves conflicts dynamically. What it generally does not yet mean is autonomous handling of soft, irregular or unpackaged food. Picking a case off a mixed pallet, grading produce, or placing a wet product reliably is a manipulation problem, not a logistics one, and it is markedly less mature than driving a pallet across a floor.
A vendor who answers a question about case picking with a demonstration of pallet transport has changed the subject. The clearest way to separate the two in a sales conversation is to ask where the uncertainty sits. Transport tolerates uncertainty well — if a route is blocked, the robot waits or reroutes, and nothing is damaged. Handling does not; a 95-percent-reliable gripper on a glass-jar line is a cleanup crew.
What this means for different operations
For a large processor with multiple buildings and a stable high-volume line, fixed automation — conveyors, monorails, automated storage — is still usually cheaper per move. The case for an adaptive fleet grows as variability grows: contract manufacturers, seasonal co-packers, multi-SKU chilled operations, and anyone whose warehouse layout changes more than once a year. For mid-sized producers, the real draw is the capital profile rather than the headcount. Vehicles are bought incrementally and can be redeployed to another task or another building, which fits a business that cannot write a seven-figure check against a five-year layout forecast.
That flexibility is the actual product; the autonomy is how it is delivered. The labor argument deserves precision. These systems displace repetitive long-haul transport — forklift trips from line end to warehouse — which is also where a large share of plant injuries and near-misses occur. They do not displace the people who clean, changeover, troubleshoot or inspect, and plants that automated transport usually find they need more technical maintenance capability, not less.
How to evaluate a food-plant deployment
Specific questions separate a project that works from one that stalls in month four:.
- Ask for the washdown and ingress rating of the exact configuration you would buy, not the product family, and ask what happens to it after two years of caustic exposure.
- Map your temperature transitions and ask how the vehicle handles condensation on its sensors when crossing them.
- Check how the fleet talks to your warehouse management and production systems. An order has to come from somewhere; manual tablet dispatch is a pilot, not an operation.
- Test with your worst pallet, not a clean one — broken stringers, shrink-wrap tails, overhang, a slip sheet.
- Confirm who maintains the map when racking moves, and whether that is a customer task or a service visit.
The integration layer is where projects actually fail
The robots are the visible part and rarely the hard part. Most disappointing deployments trace back to the information layer: the plant could not reliably tell the fleet what to move, when, and to which location, because that knowledge lived in a supervisor's head or on a whiteboard. A swarm that allocates jobs intelligently still needs correct jobs. If your locations are not uniquely identified, your inventory record does not match the floor, or your production system cannot emit a "pallet ready at line three" event, the autonomy has nothing to be autonomous about.
Plants that sort out location accuracy and event triggers before buying vehicles consistently commission faster. Start by instrumenting one loop end-to-end — a single line to a single staging lane — and run it manually with forklifts against the data your systems produce. If the digital record of that loop is accurate for a month, the loop is ready to automate. If it isn't, no amount of onboard intelligence fixes it.
Frequently Asked Questions
Can these robots work in a wet processing area?
Generally not in the food-contact zone. Hygienic design and sustained washdown exposure are the blockers, which is why current deployments concentrate in packaging halls, warehouses and dock areas.
Do I need to install guidepaths, tape or reflectors?
Not for feature-based navigation of the kind AGILOX uses. The vehicle localizes against the building itself, though you still need someone accountable for updating the map when racking changes.
How does a swarm fleet differ from a conventional AGV fleet in practice?
Jobs are allocated by the vehicles rather than a central server, so there is no fleet-manager single point of failure and adding a unit is a configuration step rather than a system redesign.
Will this replace forklift operators?
It mainly absorbs repetitive long-distance transport. Expect reallocation toward changeover, cleaning and maintenance work, and plan for added technical support capability rather than a straight headcount reduction.